

Physical AI Data Infra,from human for human.
Joined September 2025
- Tweets62
- Following42
- Followers1.3K
- Likes38




We release Gen-HumanWholeBody, an egocentric whole-body manipulation dataset with industry's highest precision. The dataset is now open-source! 🚀 huggingface.co/datasets/genr…
🚶600 hours of whole-body manipulation data
🎯 ~3 cm whole-body MPJPE
🌍 16,976 real-world scenarios
🦾 1,281 human skills
We’re opening this dataset to help researchers and developers advance whole-body motion learning, human-to-robot transfer and embodied foundation models.
Contact Us:[email protected]
Discord: discord.gg/rSSb5thgu


How do you scale whole-body data?
😜Start with Ego!
Vision-only,whole body mesh!
≈3 cm whole-body error
100K hours/month.
From real-world human behavior to policy-ready Whole-Body Manipulation Data—at scale.
See the Whole Body.
Learn the Whole Skill.
#PhysicalAI #Robotics
Genrobot.AI retweeted
Huge congrats again, @dreamlabs_ai! Proud to partner with you. 🤝🚀

Special Shoutout to our friends in @anvil_robotics @AGIBOTofficial @MeckaAI @xdofai @robocurve @cortexairobot @makermodsai @GenrobotAI @eastworlds_io @BitRobotNetwork @ScaleAILabs @LeRobotHF @huggingface @roborobots @ROBOTIS for helping us with our early beta testing across Asia, Europe, and the Americas Europe and America 🌍.
A truly global stress test of Dream-1 before our launch!
Genrobot.AI retweeted

Today, Dream Labs is coming out of stealth with Dream-1, a robot foundation model that controls bimanual robots it has never seen, on tasks it was never shown, in places it has never been, from $3/hour.
Dream API is live for everyone, today. 🧵
Genrobot.AI retweeted
Special Shoutout to our friends in @anvil_robotics @AGIBOTofficial @MeckaAI @xdofai @robocurve @cortexairobot @makermodsai @GenrobotAI @eastworlds_io @BitRobotNetwork @ScaleAILabs @LeRobotHF @huggingface @roborobots @ROBOTIS for helping us with our early beta testing across Asia, Europe, and the Americas Europe and America 🌍.
A truly global stress test of Dream-1 before our launch!
Huge congrats again, @dreamlabs_ai! Proud to partner with you. 🤝🚀
Special Shoutout to our friends in @anvil_robotics @AGIBOTofficial @MeckaAI @xdofai @robocurve @cortexairobot @makermodsai @GenrobotAI @eastworlds_io @BitRobotNetwork @ScaleAILabs @LeRobotHF @huggingface @roborobots @ROBOTIS for helping us with our early beta testing across Asia, Europe, and the Americas Europe and America 🌍.
A truly global stress test of Dream-1 before our launch!
Congrats @dreamlabs_ai on launching Dream-1!
We’re honored to be a launch partner for Dream-1.
Today, Dream Labs is coming out of stealth with Dream-1, a robot foundation model that controls bimanual robots it has never seen, on tasks it was never shown, in places it has never been, from $3/hour.
Dream API is live for everyone, today. 🧵
Congrats to Nature Will on the launch of Natura-1! 🚀
We’re proud to see our real-world data powering Natura-1, Nature Will’s first general-purpose foundation model.
Honored to be part of this journey.

That’s a wrap on #IROS2026!
What an incredible few days in Pittsburgh.
A huge thank you to everyone who stopped by GenRobot Booth 637 — researchers, builders, industry partners, and robotics enthusiasts from around the world. We loved the conversations, questions, ideas, and connections around Human Data for Embodied AI.
Every conversation gave us new perspectives on what the next generation of Physical AI needs — and motivates us to keep pushing forward.
We’re just getting started. We’ll keep turning real-world human experience into new possibilities for embodied AI.
Thank you, Pittsburgh. See you at the next one! 👋

Congratulations to our partner Simate on developing its proprietary Physical RSI system and taking the top spot on the RoboDojo leaderboard!


🏆 Congrats to our partner Simate! Simate-beta ranks #1 on RoboDojo-Sim’s Long-Horizon benchmark.
Built with our data collection hardware.
Trained entirely on our data.
Proud to help robots take on longer, more complex tasks. 🚀
#Genrobot #Robotics #EmbodiedAI

Get it running now👉genrohub.com/blog/gen-human-…
Introducing Gen-HumanEgo, a more training-ready open-source egocentric human data for robot learning.
Powered by our Data Foundation Model (DFM), synchronized Ego video is transformed into training-ready signals: video, action, robust hand tracking, depth, semantic annotations are precisely aligned and encoded into unified tokens — creating a shared representation.
We are here to turn real-world human experience into training-ready data, designed to help models learn better.
Gen-HumanEgo is a start.
#EgoData #Opensource #EmbodiedAI
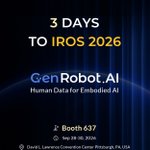
3 days to IROS 2026.
GenRobot.AI is getting ready to meet the researchers, builders, and innovators shaping the future of embodied AI in Pittsburgh.
We’re bringing our latest work on Human Data for Embodied AI to Booth 637.
Come explore how diverse, real-world human data can help scale Physical AI beyond the lab.
📍 Booth 637
📅 Sep 28–30
📌 Pittsburgh, PA See you at IROS.
#IROS2026 #EmbodiedAI #HumanData #PhysicalAI #Robotics

Genrobot.AI retweeted
Introducing Gen-HumanEgo, a more training-ready open-source egocentric human data for robot learning.
Powered by our Data Foundation Model (DFM), synchronized Ego video is transformed into training-ready signals: video, action, robust hand tracking, depth, semantic annotations are precisely aligned and encoded into unified tokens — creating a shared representation.
We are here to turn real-world human experience into training-ready data, designed to help models learn better.
Gen-HumanEgo is a start.
#EgoData #Opensource #EmbodiedAI
Introducing Gen-HumanEgo, a more training-ready open-source egocentric human data for robot learning.
Powered by our Data Foundation Model (DFM), synchronized Ego video is transformed into training-ready signals: video, action, robust hand tracking, depth, semantic annotations are precisely aligned and encoded into unified tokens — creating a shared representation.
Open-source now: huggingface.co/datasets/genr…
Join our Discord community to connect with the team and other builders: discord.gg/rSSb5thgu
Contact Us: [email protected]

Swinging. Turning. Jumping.
@GenrobotAI DFM turns six-camera Ego video into continuous whole-body mesh and skeleton data, preserving body structure and temporal consistency even during fast motion and complex poses.
See the Whole Body. Learn the Whole Skill.
#GenRobot #WholeBodyData #egodata
#PhysicalAI #Robotics
Bending. Squatting. Moving.
DFM reconstructs continuous whole-body meshes from Ego video, even with partial occlusion.
~3 cm mean whole-body error.
See the Whole Body. Learn the Whole Skill.
#GenRobot#WholeBodyData#ego data
#PhysicalAI #Robotics
IROS 2026|Meet @GenrobotAI in Pittsburgh – Human Data for Embodied Intelligence
We are excited to announce our participation in IROS 2026! We warmly invite researchers, industry leaders, and innovation partners from around the world to join us in Pittsburgh. Together, we'll delve into the frontier of embodied AI, explore breakthroughs in perception-action integration, and discuss pathways to real-world impact across industries.
📅 Date: September 28–30, 2026
📍 Venue: David L. Lawrence Convention Center, Pittsburgh, USA
📌 Booth: 637
We look forward to connecting with you in Pittsburgh — and exploring the future of embodied intelligence through Human Data together!
#Genrobot #humandata #egodata
