

Robotics for the onchain era. Autonomous companions with a secure element at their core.
Joined October 2026
- Tweets60
- Following12
- Followers238
- Likes27




Pinned Tweet
Lamport Robotics is live on @machinedotfun
D4CzGsZgusVj2K8R1its5H8WWdo9mazbDwBc6qvsmfun
We make robots that hold their own keys, and the software, models and tools around them. What exists, what is early, where it goes.
🧵↓
Introducing Lamport Sieve.
Robots are being trained on data nobody has watched. Sieve watches. We pointed it at 400 human teleop demos: 10 thrown out for drops and collisions, 73 flagged, a wrist servo out of calibration across 3 tasks that nobody had noticed.
Then we trained on it. Deleting the bad demos made it worse. Keeping them at 1/5 weight beat everything.
Audit your LeRobot repo, free: lab.lamportrobotics.com/audi…
The 8 audited sets, with reports and weights: huggingface.co/LamportRoboti…

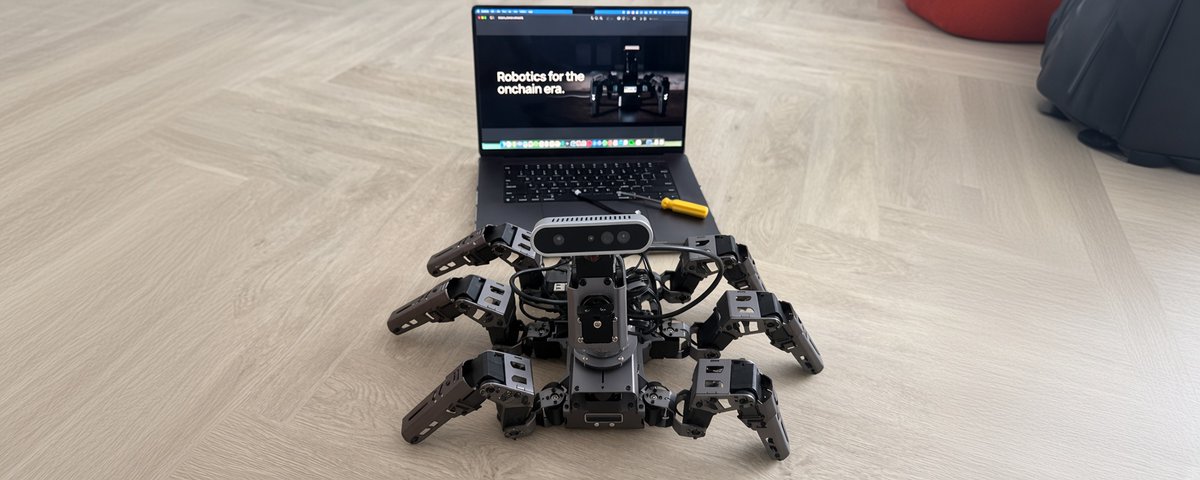
Pincer1, from first part to first walk.
~40 components, 22 servos, keys in an NXP SE050.
lamportrobotics.com/features
Servo thermals while it walks. 18 leg servos share one half-duplex serial line, so I poll temperature 3 servos at a time every 250 ms, between gait commands. Positions at 45 Hz, lidar at 7. Hottest after a few minutes: a femur at 64°C, limit 85. Coxas stay near 45.
Lamport Robotics retweeted

Love seeing all these creative robotics builders bringing their cute, funny, but also genuinely useful robots to life, alongside the enterprise machines coming to peaq.
Some are already running peaqOS, and @machinedotfun is paving the way for many more to run peaqOS once deployed, becoming transparent onchain assets that can do business onchain.


We’re training our own model, Lamport-4B. Small enough to run inside Pincer1 with no internet. Its one job is reading a transaction before the robot signs it: which program, what it does, who gets control of what. Keys never leave the robot.
github.com/Lamport-Robotics
Pincer1 has a second password. Say it under pressure and it opens a decoy wallet, locks the real one, and quietly tells the people you picked where the robot is. The person next to you sees a wallet. Your friend sees the alert.
Everything else it does: lamportrobotics.com/features

We also built a robot lab that runs in a browser tab.
Upload your URDF, or describe a robot and the lab builds it. Push it, drop it, tilt the floor, send it up the stairs. Every robot takes the same tests and gets a report card, so the numbers compare.
Then hit train. A GPU learns a walking gait for your robot and sends it back into the same tab. Free.
lab.lamportrobotics.com

No cable. Test chassis has a small pack, ~25 min.
Pincer1 gets a 200Wh pack: 160+ min walking, idles all day, walks to its own charger below 20%.
Full feature list is here if you want the rest: lamportrobotics.com/features
Lamport Build is live for Mac.
A coding agent with free open models built in, and our own model on top.
Hold 50,000 $LAMPORT and the whole thing is free, no limits.
Sessions you choose to share train Lamport’s own models.
curl -fsSL lamport.si/install | bash
Locked 149,262,686 LAMPORT, 14.9% of supply, until 1 Nov 2027.
app.streamflow.finance/contr…

What comes next:
– Pincer1 first batch to the waitlist
– robotic hands with the same secure-chip signing, able to pick things up
– running shoes that record how people actually move, so the robots learn from real gait
– a data pipeline: everything the robots walk, climb and handle goes into our own models
Waitlist: lamportrobotics.com/presale
Everything in one place: lamportrobotics.com/links
Code: github.com/Lamport-Robotics
Telegram: t.me/lamportrobotics