
Postdoc @UvA_Amsterdam | world models and sensorimotor abstractions |👾🤖🧠
Joined October 2021
- Tweets56
- Following174
- Followers201
- Likes112


Pinned Tweet
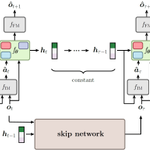
World models are key for developing adaptive agents. In our #ICLR2024 spotlight we present THICK: an algorithm to learn hierarchical world models with versatile temporal abstractions. And we show how they can enhance model-based RL or planning…
📜 openreview.net/forum?id=TjCD…
1/🧵
Christian Gumbsch retweeted

🚀 Announcing #RSS2026 workshop: Robot World Models 🌐🤖🐨🌐 July 17, 2026 in 🇦🇺!
We're bringing together researchers building the next generation of WM for robots — models robots can act in: controllable, long-horizon & grounded in real dynamics. 🔗 robot-worldmodels.github.io

Christian Gumbsch retweeted
🤖 🌍 We have extended the submission to our CoRL (@corl_conf) workshop about Robot World Models for one more week! Use your chance to submit! 🌏🤖
❗️Both 1-page abstracts of published works and 4-page novel works in progress are welcome!
📡 Details: simulatingrobotworlds.github…

🚀 We’re excited to announce our #CoRL2025 workshop: Learning to Simulate Robot Worlds
Spanning high-fidelity simulators, digital twins, and learned world models - our goal is to unite communities to push robot learning forward 🤖🌐
🔗 simulatingrobotworlds.github…
🧵🧵🧵
Christian Gumbsch retweeted

Introducing DINOv3 🦕🦕🦕
A SotA-enabling vision foundation model, trained with pure self-supervised learning (SSL) at scale.
High quality dense features, combining unprecedented semantic and geometric scene understanding.
Three reasons why this matters…

Christian Gumbsch retweeted
Are you working on real-to-sim, sim-to-real, learning world models, or using physics-based simulators? There are two weeks left until the submission deadline for our CoRL workshop, Learning to Simulate Robot Worlds. More details here:
🔗simulatingrobotworlds.github…
Christian Gumbsch retweeted
🚀 We’re excited to announce our #CoRL2025 workshop: Learning to Simulate Robot Worlds
Spanning high-fidelity simulators, digital twins, and learned world models - our goal is to unite communities to push robot learning forward 🤖🌐
🔗 simulatingrobotworlds.github…
🧵🧵🧵
Christian Gumbsch retweeted

@svlevine was just presenting in the Exploration in AI @ #ICML2025 and promoted that exploration needs to be grounded, and that VLMs are a good source ;-) Check our paper below
👇


✨Introducing SENSEI✨ We bring semantically meaningful exploration to model-based RL using VLMs.
With intrinsic rewards for novel yet useful behaviors, SENSEI showcases strong exploration in MiniHack, Pokémon Red & Robodesk.
Accepted at ICML 2025🎉
Joint work with @cgumbsch
🧵
Christian Gumbsch retweeted

Zero-shot imitation from just a single sparse demonstration is hard. Goal-conditioned methods tend to “greedily" move from one state to the next and lose the big picture.
We're presenting an alternative approach on Tuesday at #ICML2025.
(1/3)
Christian Gumbsch retweeted

When multiple tasks need improvements, fine-tuning a generalist policy becomes tricky. How do we allocate a demonstration budget across a set of tasks of varied difficulty and familiarity?
We are presenting a possible solution at ICML on Wednesday!
(1/3)

Christian Gumbsch retweeted

✨Introducing SENSEI✨ We bring semantically meaningful exploration to model-based RL using VLMs.
With intrinsic rewards for novel yet useful behaviors, SENSEI showcases strong exploration in MiniHack, Pokémon Red & Robodesk.
Accepted at ICML 2025🎉
Joint work with @cgumbsch
🧵
Christian Gumbsch retweeted
How to represent dynamic real-world data both consistently and efficiently, while reflecting the compositional object-centric structure of the world?
Contrast your slots!
...with our new SlotContrast method(🚀#CVPR2025 Oral🚀)!
🌐website: slotcontrast.github.io
🧵🧵🧵 1/n
Christian Gumbsch retweeted

#Context plays a critical role not only in interpreting language but many other cognitive processes. In a new paper, we propose that context-sensitivity is a core feature of human memory that enables flexible planning, #generalization, and decision making doi.org/10.1016/j.neubiorev.…

Christian Gumbsch retweeted

Were you ever wondering why there are little-to-no diverse offline imitation learning algorithms 🤔? Then we've got something 4 you! Our paper, "Offline Diversity Maximization under Imitation Constraints" is being presented today at RLC2024 🎇! 🧵
rlj.cs.umass.edu/2024/papers…

Christian Gumbsch retweeted

🚨We're back!🚨 Excited to announce The 2nd IMOL Workshop at #neurips2024!
Send us your 📜newest work📜on learning & exploration in artificial and biological agents. #CFP at imol-workshop.github.io/page…
🔄Please share widely & stay tuned for more programming announcements!

Christian Gumbsch retweeted

Tired of causally confused agents when learning from offline datasets?
We propose 🚣🏼♀️CAIAC🚣🏼♀️, a method for counterfactual data augmentation to improve the robustness of offline learning agents against extreme distributional shifts at test time. 🧵
Christian Gumbsch retweeted

🚨Introducing GenRL!
An embodied AI agent that learns multimodal foundation world models 🌍
By connecting the multimodal knowledge of foundation models with the embodied knowledge of world models for RL, GenRL enables turning vision and language prompts into actions!
THICK PlaNet 🪐: We can also plan directly with our model. In THICK PlaNet we first plan on the high level with MCTS and then we search for low-level actions to follow this plan. This is useful for long-horizon or hierarchical tasks and sparse rewards.
7/8

For more details check out our paper or our code.
Paper 📜: openreview.net/forum?id=TjCD…
Code 🐍: github.com/CognitiveModeling…
Many thanks to @nsajidt, @GMartius, and @mvbutz!
8/8