

Engineer, software developer. Currently making robots for fun.
Melbourne, Australia
Joined December 2008
- Tweets2K
- Following551
- Followers521
- Likes837






Pinned Tweet
Started building robots. Everyone needs a hobby right!
Two actuators in this are small brushless motors with integrated drivers controlled via CAN. Wheels for now, but the idea is to step up to legs next.
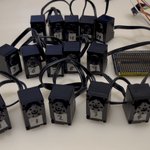
Finally have all the electronics sorted for the Unitree J288 Microduck. Just waiting on some 3d printed parts now so it can actually start to look like a duck.
The 15 servos are now happily talking.
An STM32 handles the 6 Mbps Unitree servo buses and interfaces with the body IMU. Three UARTs each handle a group of 5 servos, while a 4th UART sends all the details to the Radxa CM4, the robot’s brain.
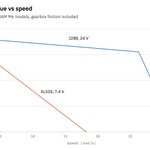
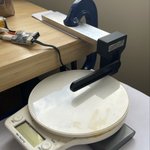
Static stall tests showed the Unitree J288 having similar torque to the Dynamixel XL330-M288-T. J288 weighs twice as much, so some concern my robot may not hold its weight. More positively, the J288 is a lot faster (expected) and also maintains torque over its speed range better.

That chart does not show real data, it’s modelled from the XL330 actuator in BAM and a new J288 model I worked through the identification for.
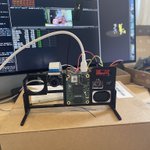
Eventually all this needs to fit in a microduck head, for now I’m just happy it’s working. Camera, ToF sensor, mic/amp are all the same as the official build. Radxa CM4 differs to the Zero 3W, but the duck brain code runs just fine.

For Father’s Day my daughter made this extremely cute micro-Microduck 🥹. Lacks a few DOF, still has a lot of personality.

Developed an interest in those tiny FPV drones. The analog video stuff is interesting and felt approachable enough to hack a decoder+fpga+display to start doing some cool stuff. Feels very low latency, as it should be, also very retro. Details here github.com/lachlanhurst/fpga…

If this dude runs STS3215 servos, my SO-100 might be on borrowed time.

Thrilled to finally share what we've been working on for months at @huggingface 🤝@pollenrobotics
Our first robot: Reachy Mini
A dream come true: cute and low priced, hackable yet easy to use, powered by open-source and the infinite community.
Tiny price, small size, huge possibilities. A robot built to code, learn, share with AI builders of all ages, all around the globe, using the latest vision, speech and text AI model. A first robot for today's and tomorrow's AI builders.
Read more and order now at hf.co/blog/reachy-mini
First deliveries expected right after the summer.
Those dropped IMU packets seemed to be due to a bad connection rather than a SW issue I spent hours debugging. New breadboard seems to have fixed it, also fixed the hum emanating from the OLED.

Wrote a MuJoCo simulation and control app for the so100/so-arm100 . Supports recording/playback and teleop'ing the sim. Needed something to keep me busy waiting for the parts to print out.
Details and code here -> github.com/lachlanhurst/so10…
Thanks @LeRobotHF & @therobotstudio 🙌
After some tweaking sim2real transfer of policy is going well. Reward function doesn’t penalise for moving, so it just roams about.
Interestingly the RL policy doesn’t overreact on collisions like the PID/LQR balance controller does. It just runs into something, stops, and then pirouettes off. LQR left, policy right.

Started off with a simple PID controller for balance, then cascaded PIDs, and finally settled on an LQR controller. This works well, but the hope is switching to a policy trained up via reinforcement learning will give more robust “disturbance rejection”.
Code for the RL stuff is up on GitHub. Plan is to do a full release of the robot CAD/STLs, Gerbers, code at some point in the future.
github.com/lachlanhurst/bala…
