
Robotics Ph.D. student at Carnegie Mellon!
Joined July 2019
- Tweets62
- Following157
- Followers74
- Likes2.5K


Pinned Tweet
Spot dressed up for Halloween!🎃 It's on a mission for its favorite 'candy'! 🔋 But two 'ghosts' were blocking the path…
A fun demo of our new paper on how robots can intelligently 'make way' on cluttered stairs! (1/4) @CMU_Robotics
Sharing this work that I was partially involved with at @multiplylabs
We show that using contact information as feedback signal during training can help track grasps even on new, unseen objects. All demos are open loop. Excited to show this work.
Project page and video: multiplylabs.github.io/oath/
Paper: arxiv.org/abs/2610.14379


Prasanna Sriganesh retweeted

In OATH, we introduce a single reference-, object-, geometry-, and task-agnostic policy that achieves physically feasible retargeting by leveraging contact error as a feedback signal. Excited to share our work!
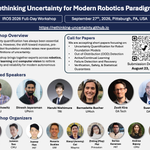
Do we still need Uncertainty Quantification for robotics? What does uncertainty mean in the modern robotics paradigm?
💡 We are organizing a workshop “Rethinking Uncertainty for Modern Robotics Paradigms” @ IROS 2026
Submit your work by Aug 23! 👇 (rethinking-uncertainty.githu…)

Organized by: Prasanna Sriganesh (CMU), @Junwon__Seo (CMU), Juyeop Han (MIT), Rosario Scalise (UW), Xiaoyi (Jeremy) Cai (Waymo), Zhiting (May) Mei (Princeton), Sertac Karaman (MIT), @andrea_bajcsy (CMU) | Matthew Travers (CMU)
🔗 Website & CFP: rethinking-uncertainty.githu…
Submission Deadline: August 23, 2026 (AoE)
Workshop Date: Sept 27, 2026
Location: Pittsburgh, PA
A planner then computes safe trajectories, which are executed by a learned pedipulation policy.
This tight coupling results in much higher success rates and lets the robot reclassify heavy 'immovable' objects. Here's a look at more technical results: (3/4)
See all the videos and details on our new project page: ➡️ prassi.me/clearing-clutter-o…
Full paper: 📷 arxiv.org/abs/2509.20516 (4/4)
#Robotics #Halloween2025 #AI
The code for our work on staircase perception is now public. This repository includes implementations from our papers on Bayesian staircase estimation and fast staircase detection.
Code: github.com/Prassi07/staircas…


Making robots safer on stairs! 💪 Our new work, just accepted to RA-L, introduces a clever way for robots to perceive the whole staircase, even when parts are hidden from view! 👀
Full paper: ieeexplore.ieee.org/document…
@CMU_Robotics
(1/4)
Bayesian Inference: We use this model with Bayesian inference to intelligently combine noisy sensor readings with prior knowledge about staircase already seen.
This combination lets us tackle challenges like occlusions, clutter, limited field-of-view and sensor noise.
(3/4)
But that's not all! We also use this information to segment the stair surfaces and remove clutter, enabling safer navigation on staircases. 🤖
Check out our project website for more info and images! 👉 prassi.me/bayesian-staircase…
(4/4)
Making robots safer on stairs! 💪 Our new work, just accepted to RA-L, introduces a clever way for robots to perceive the whole staircase, even when parts are hidden from view! 👀
Full paper: ieeexplore.ieee.org/document…
@CMU_Robotics
(1/4)
Prasanna Sriganesh retweeted

Hello all,
We are excited to organize the first workshop on Learning for Soft Robots at #CoRL2023! Through our amazing line-up of speakers, we hope to motivate future research in various soft robotic areas such as manipulation, locomotion, sensors, and embodied perception!

On the Friday of July 28th, I successfully finished my masters thesis on a staircase perception system for mobile robots.
Also, I'll be continuing as a Ph.D student at @CMU_Robotics this fall.

