

PhD in Computer Science candidate @Stanford. My interests span learning for robotic planning, control, vision systems, and their interfacing representations.
Stanford, California, USA
Joined November 2021
- Tweets98
- Following53
- Followers649
- Likes142



Pinned Tweet
What makes data “good” for robot learning? We argue: it’s the data that drives closed-loop policy success!
Introducing CUPID 💘, a method that curates demonstrations not by "quality" or appearance, but by how they influence policy behavior, using influence functions. (1/6)
What's your robot policy actually doing at deployment? 🤔
Behavior Graphs turn policy rollouts into a human-interpretable graph of policy behavior, so you can pin down failure modes and steer data collection for systematic improvement!
Awesome work led by @erikbauerr!

We will be presenting 3 exciting papers at
@corl_conf! 🎉
1️⃣ CUPID – Data curation for imitation learning
2️⃣ RoboMonkey – Test-time scaling for VLAs
3️⃣ FORTRESS – Safe reactive planning in OOD scenarios
Come find us at the poster sessions - we’d love to chat! Links in thread 🧵

1️⃣ CUPID: cupid-curation.github.io
- Sep 28
- Spotlight Session 2
- Poster Session 1
2️⃣ RoboMonkey: robomonkey-vla.github.io
- Sep 28
- Spotlight Session 2
- Poster Session 1
3️⃣ FORTRESS: milanganai.github.io/fortres…
- Sep 29
- Oral Session 4
- Poster Session 2
Join us @corl_conf 2025 this Saturday Sep 27th for the workshop on “Making Sense of Data in Robotics!” We have a line up of exciting talks, posters, and tutorials on all topics robotics data - from composition to intepretability! #CoRL2025

It's almost time for #CoRL 2025! A reminder that we're hosting the Data in Robotics workshop this Saturday Sept 27th. We have a packed schedule and are also attempting to livestream the event for those who can't attend in person.

See the website for program details: sites.google.com/stanford.ed…

2
174
Join the discussion on what makes robot learning data "good" at our @corl_conf workshop 🚀! Topics include data composition, curation, and interpretability. Submit by Aug 22!

We're hosting the 1st workshop on Making Sense of Data in Robotics at @corl_conf this year!
We'll investigate what makes robot learning data "good" by discussing:
🧩 Data Composition
🧹 Data Curation
💡 Data Interpretability
Paper submissions are due 8/22/2025!
🧵(1/3)
CUPID has been accepted to @corl_conf (CoRL) 2025! 🎉
We’ve also released the project code — if you’re interested in influence-based data curation for robot imitation learning, check it out: github.com/agiachris/cupid
📢 Excited to announce the 1st workshop on Making Sense of Data in Robotics @corl_conf! #CORL2025
What makes robot learning data “good”? We focus on:
🧩 Data Composition
🧹 Data Curation
💡 Data Interpretability
📅 Papers due: 08/22/2025
🌐 tinyurl.com/corldata25
🧵(1/3)

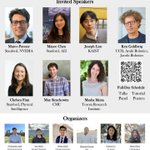
🎤 Featuring a superb lineup of invited speakers:
@drmapavone
@chelseabfinn
@JosephLim_AI
@andreea7b (tentative)
@max_simchowitz
@MashaItkina
💿 and a tutorial on data mixing by @MayeeChen !
1
8
439
Q: How can we reduce action error in VLA policies to improve performance at deployment?
💡 Scale inference-time compute via VLM-based action verification!
🔍 Check out @jackyk02's work RoboMonkey 👇

✨ Test-Time Scaling for Robotics ✨
Excited to release 🤖 RoboMonkey, which characterizes test-time scaling laws for Vision-Language-Action (VLA) models and introduces a framework that significantly improves the generalization and robustness of VLAs!
🧵(1 / N)
🌐 Website: robomonkey-vla.github.io
💻 Code: github.com/robomonkey-vla/Ro…
🗂️ Datasets and Models: huggingface.co/robomonkey-vl…
🚀 Serving Engine: github.com/robomonkey-vla/sg…
📄 Paper: arxiv.org/abs/2506.17811

If you are at RSS 2025 and interested to learn more, I will be presenting CUPID at the Robot Evaluation workshop! Details below:
- Spotlight talk, 11:00am @ RTH211
- Poster session, 4:00pm @ Epstein Plaza
Check out @Ransalu and @hocherie1's workshop!
sites.google.com/stanford.ed…

In real-world deployment settings, generative robot policies are bound to encounter out-of-distribution scenarios that cause them to fail in unexpected ways.
We present Sentinel, a runtime monitor that detects unknown failures of generative policies at deployment time!💂(1/6)
How can robots incorporate human preferences into their plans?
Introducing Text2Interaction: a long-horizon, skill-based planner that meets human preferences at the task, motion, and control levels zero-shot using code writing LLMs.
Project site: sites.google.com/view/text2i…
Check out our arXiv preprint: arxiv.org/abs/2408.06105!
Awesome collaborating with Jakob Thumm, @drmapavone, and Matthias Althoff
1
344
Points2Plans goes from natural language ➕ a single partial-view point cloud ➡️ long-horizon robot plans!
We 1) use transformers to learn skill effects in simulation and then 2) plan over learned skill effects to transfer directly to real. And yes, it can fetch you snacks (🍎)!

Links below for more details!
Project site: sites.google.com/stanford.ed…
arXiv: arxiv.org/abs/2408.14769
127
🔔‼️ I will be presenting our latest work on failure detection for generative robot policies at the #RSS2024 Toward Safe Autonomy workshop.
Check out our poster session if you're interested!
Poster Session: 3:30-4:00pm Hall C
Workshop: sites.google.com/view/rss202…

💡Interested in how LLMs can be used within a real-time reactive control framework for dynamic robots?
Check out our work at #RSS2024! Presentation by @RohanSinhaSU at 3:30pm tomorrow (7/18).
Project site: tinyurl.com/aesop-llm

❓ How can we enable real-time reactive control with LLMs for dynamic robotic systems?
At #RSS2024 we present AESOP: A 2-stage (🐢🐇) reasoning framework that uses LLMs to increase closed-loop robot trustworthiness in OOD scenarios!
Site: tinyurl.com/aesop-llm
🧵(1/6)
Future space exploration missions to unknown worlds will require spacecraft to autonomously reason, plan, and manage system health over multiple mission phases!
Project site: sites.google.com/stanford.ed…
Work w/ Issa Nesnas, @SaptarshiB1, @drmapavone
youtu.be/ejP_IDua6J0

3
3
218
I would like to thank the entire contributing team at @NASAJPL ! Guillem Casadesus Vila, Saptarshi Bandyopadhyay, David S. Bayard, Kar-Ming Cheung, Charles H. Lee, Eric Wood, Ian Aenishanslin, Steven Ardito, Lorraine Fesq, Issa A. D. Nesnas
87
Announcing new work!
We investigate the use of LLMs to disambiguate "semantic anomalies" caused by an unusual combination of elements in the scene.
See @AmineElhafsi's post for more!
Website: tinyurl.com/llm-anomaly


🔍 How can we detect system-level reasoning failures to improve the robustness of robotic systems in safety-critical settings?
We use LLMs as intelligent runtime monitors to reason over and identify potentially problematic elements in a scene! 🧠
tinyurl.com/llm-anomaly
Text2Motion is updated!
Our extended results feature a new hybrid planner that combines the strengths of search-based and shooting-based planning strategies leveraging LLMs.
arXiv: arxiv.org/abs/2303.12153
Work with @linkevin0, @drmapavone, @leto__jean!


Large language models (LLMs) can readily convert language instructions into high-level plans.
However, should we trust robots to execute these plans without verifying that they actually satisfy the instructions and are feasible in the real world?
sites.google.com/stanford.ed…
Fusing concepts from large pretrained models into maps produced by (diff-) SLAM is an intriguing idea. These maps are general, but can be queried on a per-task basis for robot planning. An interesting take on task-driven perception.
Great work by @_krishna_murthy and Co!

We are demo-ing ConceptFusion at @CVPRConf for the next three hours or so.
Stop by the demo booths to chat with me, Ali, Qiao!

Announcing new work, Text2Motion!
We explore how Large Language Models (LLMs) and learned robot skills can be used to solve TAMP-like tasks with two key considerations:
1. Plans should satisfy user instructions,
2. Plans should be feasible for execution.
Check out Text2Motion!
Large language models (LLMs) can readily convert language instructions into high-level plans.
However, should we trust robots to execute these plans without verifying that they actually satisfy the instructions and are feasible in the real world?
sites.google.com/stanford.ed…
Announcing Code Release: Taskography-API!
If you're interested in generating custom robot task planning domains in large 3D scene graphs, supported in PDDL or gym-style symbolic planning wrappers, check it out!
GitHub: github.com/taskography
arXiv: arxiv.org/abs/2207.05006