

ceo @roboticscorp, former staff roboticist Boston Dynamics
Joined September 2017
- Tweets466
- Following669
- Followers1.2K
- Likes585


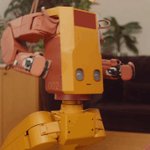


We will soon have robots in our homes. Robots with arms and legs that move through our homes like no technology has in the past.
I started @roboticscorp with the view that we should be building robots that people actually want to live with.
A home robot should be capable and it should be understandable. It should meet us where we are. And it should be a delight to live with.
All of this starts with character: engineering character into a robot means delivering a consistent experience and an understandable product. And, if done correctly, allows users to operate within existing relational paradigms. The character can be nice to have around, too.
My hope is that when you meet Voxel, he already feels somehow familiar.

Today, we’re opening up a limited number of reservations for Voxel’s first production run.
Each robot will be embossed with an edition number, assigned in the order reservations are received.
We see this number as a way to reward those who understand our vision and bet on us early.
tuesdaylabs.com/reserve


Ros Shinkle retweeted

Robotics has a distribution problem. Today, Ultra is announcing $62M in funding to solve it, including a $50M Series A led by @hiFramework.
We believe that deployment is the bottleneck in robotics.
It’s relatively easy to make a robot look impressive in a controlled environment. It’s much harder to put a robot into the open world, make it useful, keep it running, earn the trust of the people working alongside it, and do that over and over and over again.
So that’s what we’re focusing on.
This isn’t the hype cycle, it’s just another robotics company learning the same lesson that every robotics company has learned

If you build a platform you will see artificially inflated sales as everyone with enough money and interest buys 1-2 robots. Research labs buy a few more. This runs out fast. It’s definitely not a commercial strategy.

This full body teleop is so impressive, I keep rewatching the foot placement around the tool bag coming out of the kneel.

You can only learn these lessons by going out into the real world with your robot. Congrats on the results and also the choice of deployment location 😋

A video from a Pi robot deployed at Dandelion Chocolate, fully autonomous w/ no interventions. 🤖
Deploying robots has taught us surprising lessons about the gap between proof-of-concept (i.e. building one box) and real-world utility (productively building boxes for hours).
I expected that the hard part is building the box, since it’s the most dexterous, but that wasn't what we found. Counterintuitively, the hardest part was reliably stacking the boxes. Our original table-mounted robot had poor visibility of the stack without special separately-mounted cameras. Plus, stacking requires more generalization (each box is placed in a different location), and an imprecisely-placed box can lead the entire stack to collapse many boxes later.
We recently switched this deployment over to a mobile robot, and it's fun to watch the robot being completely self sufficient for multiple hours. 🙂 Data and feedback from real world use-cases like these are quite valuable for the π pre-trained model as we scale!


