

Postdoc @berkeley_ai. Researcher @IBMResearch. PhD @TelAvivUni. Working on Multimodal Robot Foundation Models and Structured Physical AI.
Berkeley, CA
Joined March 2017
- Tweets2.6K
- Following941
- Followers2.1K
- Likes8.9K




Oh WoW
It doesn’t mean that P = NP, but it does say that the NP-complete problem over n variables can be solved in much less than 2^n time.
Amazing

Here's a direct link to OpenAI's PDF claiming a refutation of ETH. In particular, it's claimed that 3SAT on n variables is in about exp(n/(log n)^{1/2+o(1)}) time
github.com/openai/math/blob/…

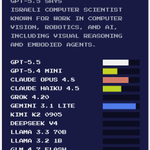
Wild that OpenAI pulled out a graph to convince me to stick with Opus 5.5 😂


Our new paper shows how coding and action prediction can be unified in a single model! Check this out!
Amazing work by @liu_zhuoyang13 and @Dantong_Niu

We're excited to introduce AW-0: Agentic World Action Models! 🤖 (0/8)
The first World Action Model that plans in code, predicts the future, and controls the robot—all in one generative model.
AW-0 jointly generates:
🧠 Code - explicit skill calls, object arguments, and control flow
🎥 Future video - predictive visual dynamics
🦾 Robot actions - continuous motor control
All three are generated together through joint denoising, letting semantic plans directly shape both predicted futures and robot behavior, with:
🤝 Hybrid execution — generated programs can also run directly through perception and control APIs
⚡ Just 40 ms of additional inference latency over the base WAM on an RTX 5090
📚 Pretrained on ~3,000 hours of robot + human demonstrations
One model for planning, prediction, and execution.
🌐 Project: agentic-wam.github.io/
📄 Paper: arxiv.org/abs/2610.30136v1
💻 Code: github.com/ZhuoyangLiu2005/a…
🤗 Model: huggingface.co/miniFranka/ag…
🧵 How it works—and what we found ↓
Very, very cool! But if you want International academic labs to participate, you’ll need to provide the hardware...

The AI physical Olympics will be held in Tel Aviv 🇮🇱!! Details and registration below!
Tel Aviv, May 18–19, 2027. 10,000 people in the arena.
Forget scripted, pre-recorded demos where the robot succeeds on take 47. This one will be live!
The P.AI Games—organized by the Israeli National AI Directorate | Prime Minister's Office and led by Guy Altagar—is putting embodied AI to the ultimate test:
10 real-world arenas. $1.35M in prize money. Live scoring in front of an arena crowd.
Here are the events:
→ Pick up oily crystal glasses and pack a dishwasher in under 8 minutes without cracking one.
→ High-speed dynamic baton handoff between two moving robots across a 20-meter track.
→ Face off in real over-the-board chess against another robot, moving pieces and hitting the clock.
→ Balance a raw egg and a full tray of water up an incline ramp with zero spills.
→ Grab a 14-lb bowling ball and take down a full rack of pins.
Humanoids, quadrupeds, wheeled bases, custom manipulators—every morphology is welcome. Whether you want to dominate a single niche challenge or take on all ten, this is where the bar gets set.
No entry fee. Plus, participating teams receive dedicated financial support to make the trip happen.
If you run a robotics startup, lead an OEM team, or build cutting-edge embodied models in academia, this is your arena.
Drop a comment or DM me if your team wants to throw their hat in the ring—I'd love to see you on the floor.
Details and registration: pai-games.com/
The winner for today 🏆

Very (very) cool! I wonder how many opportunities this creates for academic labs through an open API.

Well, AI tools usually don’t produce very polished writing on their own...
So if the paper feels very polished, I think they did a good job using them.
Playing for the win! Nice work 🥳

We taught a robot to play!
Introducing Dexterity from Supervised Play (DSP): turning minutes of human play into a world model and dexterous manipulation policy. No task demonstrations or sim2real!
play-policy.github.io
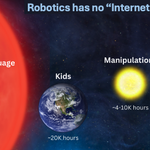
@grok How long will it take humans to collect data compared to the data that exists on the web today?
The current frontier ML paradigm has an "internet of data" to learn from. Robotics has no "Internet".
Just to be clear, I think the argument here is orthogonal to this work.
This is very cool work and probably shows the first way how it can be achieved.
I was just commenting on the general comment, unrelated to the work.😃
I agree that robots do not necessarily need to learn like humans.
But even if you don’t care about efficiency, humans are already a working example, and (for whatever reason) they are efficient. That suggests that efficiency is one solution that can work for robots too.
That’s not true. Capability should come with efficiency.
Have you seen a kid grasping all the objects in the world before he manipulates a new object?
Like compression in information theory, once you’re data-efficient, you’ve captured the structure that leads to generalization.

